Veles Systems · motion data for robot-learning teams
Human motion your robot team can train on.
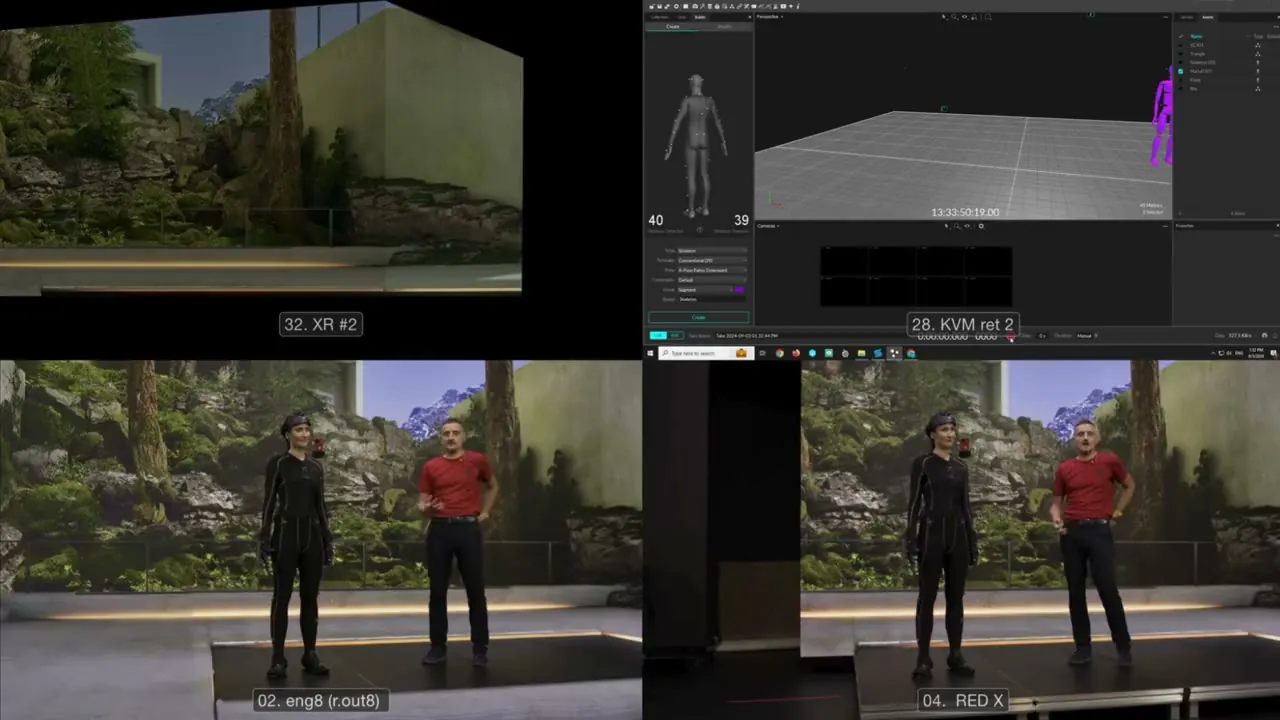
A person does the task on our capture floor in Warsaw. We map the motion onto a humanoid model and export it in open robot-learning formats. You keep your own robot platform.
Jan Kontek reads your task list and replies within two working days, saying what we can capture for it and what we can't.
From the capture floor to your stack
Someone does the task on our floor.
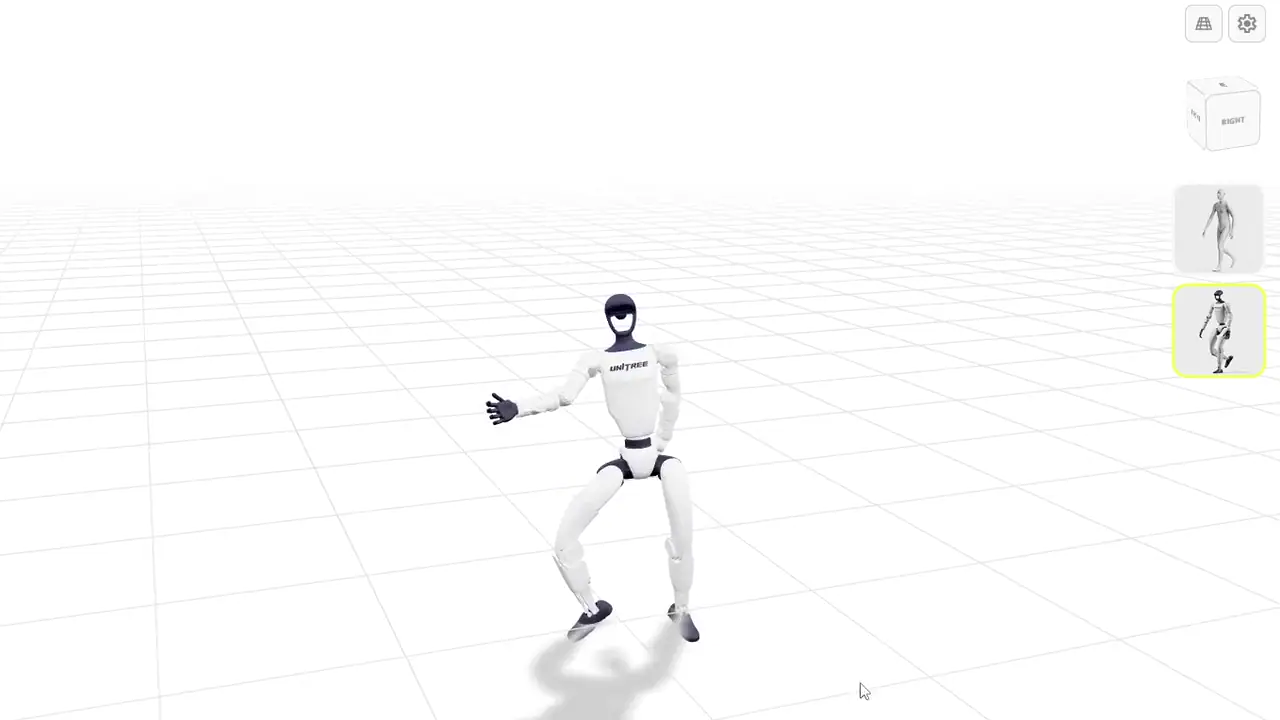
A humanoid replays it, joint for joint.
You get files your training stack can open.
Exported to open robot-learning formats.
Read the R&D case →Screen captureFrom our motion viewer: real captured motion on a humanoid model.
Honest status
Ten clips is a demo, not a dataset. We know.
We ran it once, on ourselves: ten clips, a 78-joint retarget to a humanoid, and one policy checkpoint trained on two clips. That proves the whole chain works. It doesn't prove the data suits your task. We have no closed-loop evaluation yet, and no robotics client yet. Your task list is how we find out.
The pipeline
Four steps. We ran all of them ourselves first.
We ran the chain on ourselves first, because there was no robotics client to run it for.
- Capture
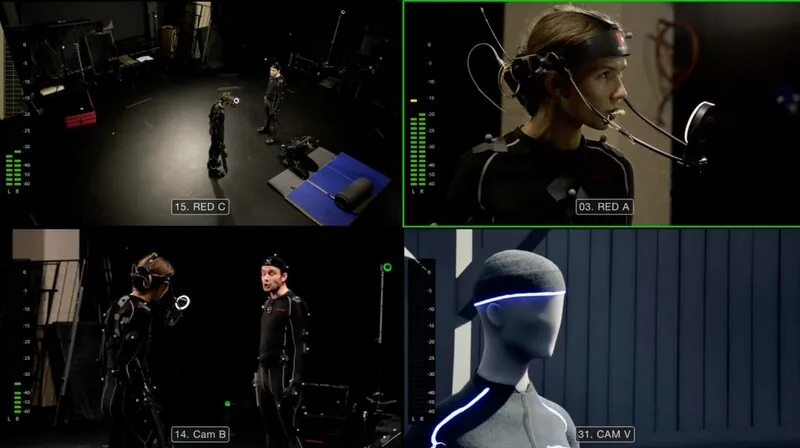
- OptiTrack optical motion capture: body, hands and props
- Mapped to robot
- Motion mapped onto a humanoid with 78 joints
- Export
- Open robot-learning formats. Ten clips run through so far.
- Train
- One robot model (policy checkpoint), trained on two clips
What an ML lead asks us first.
Where do we get human motion data we can train on?
From our capture floor in Warsaw. We've run the whole chain ourselves: optical capture, a 78-joint retarget to a humanoid, export to open robot-learning formats, and one policy checkpoint trained on two clips. Send the task and the format you train in. Jan tells you what we can and can't deliver.
Can we see a sample before we commit?
Ask Jan, with the task and your target format.
Send Jan the task list.
Jan Kontek reads it and replies within two working days, saying what we can capture for it and what we can't.
Same floor, other uses